InternshipUCL Hawkes Institute
October 2026
A MuJoCo simulator built from the CAD model of the OmSR eye-surgery robot, a Gymnasium environment with four surgical tasks, and the specification errors that policy training exposed.
ProjectRobot learning
November 2026
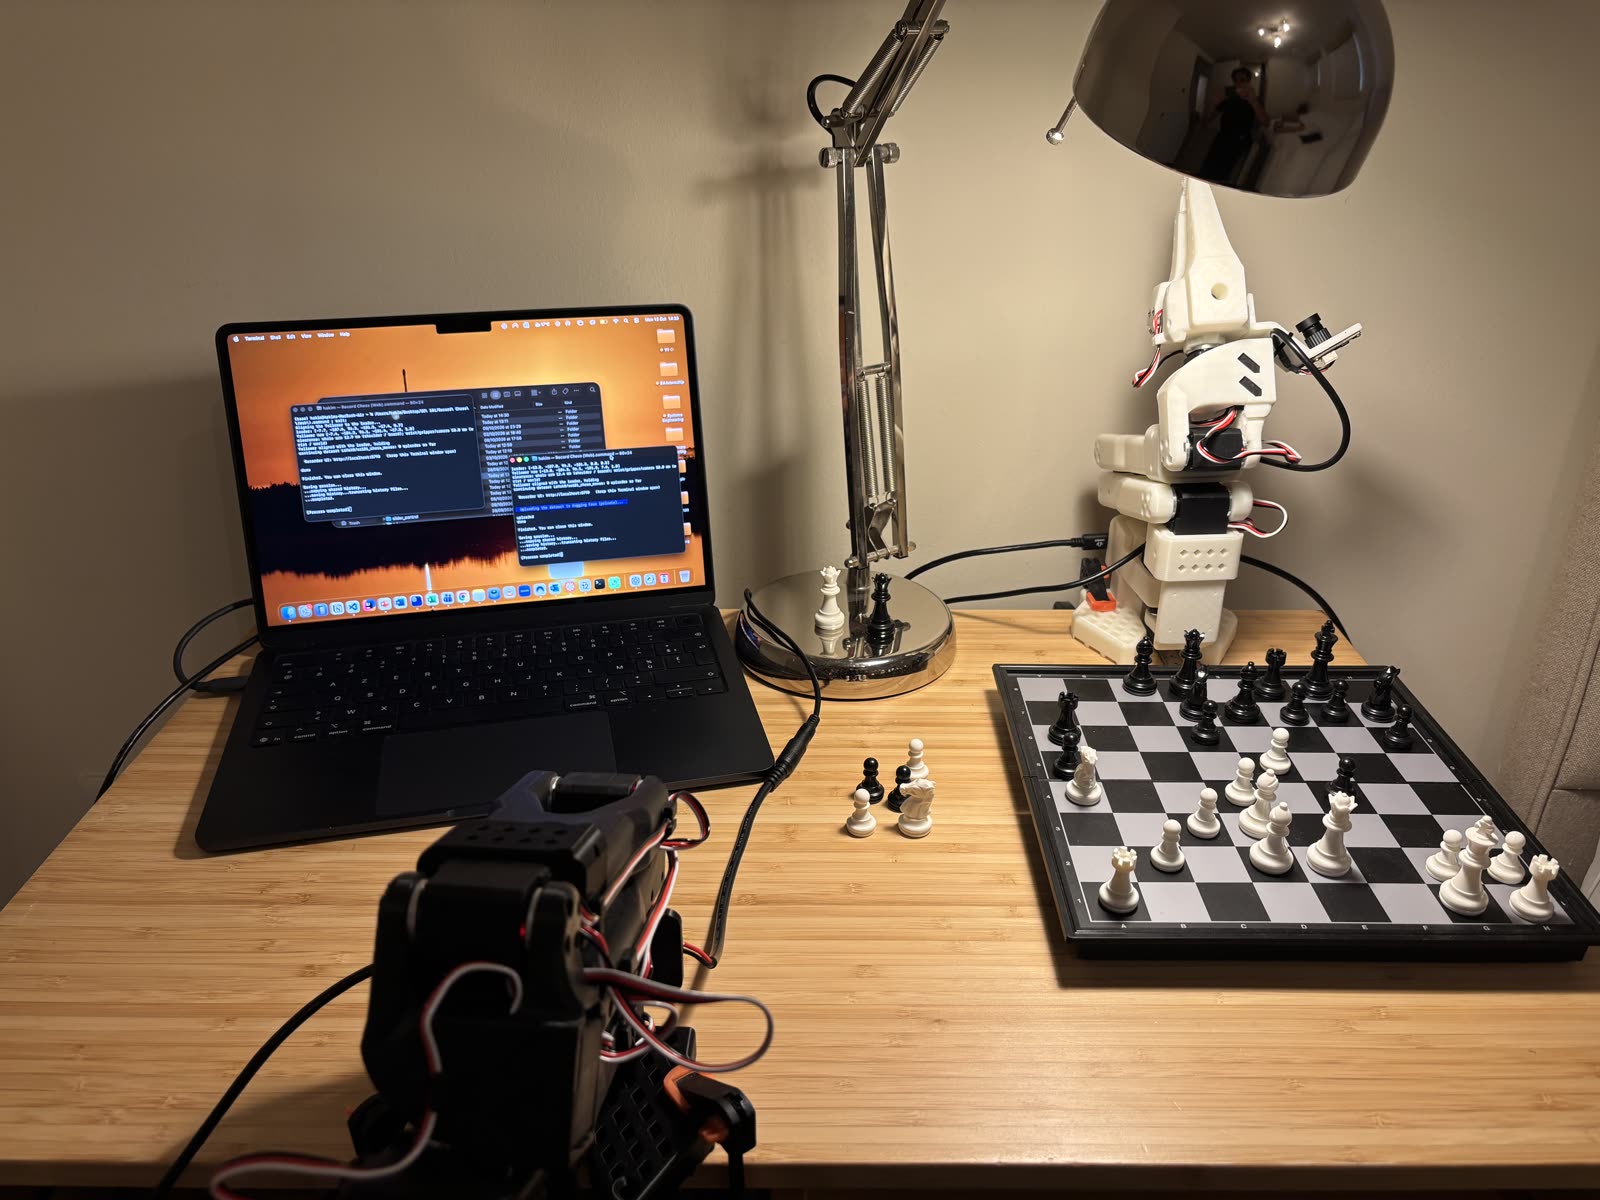
A low-cost arm playing black with one wrist camera as its only view of the board: teleoperated demonstrations, a fine-tuned SmolVLA policy, and the calibration work that most of the errors came down to.
ProjectConnectome models
October 2026
The male fruit fly connectome with its wiring kept fixed and only the connection strengths trained on chess positions, with an in-browser version you can play against.